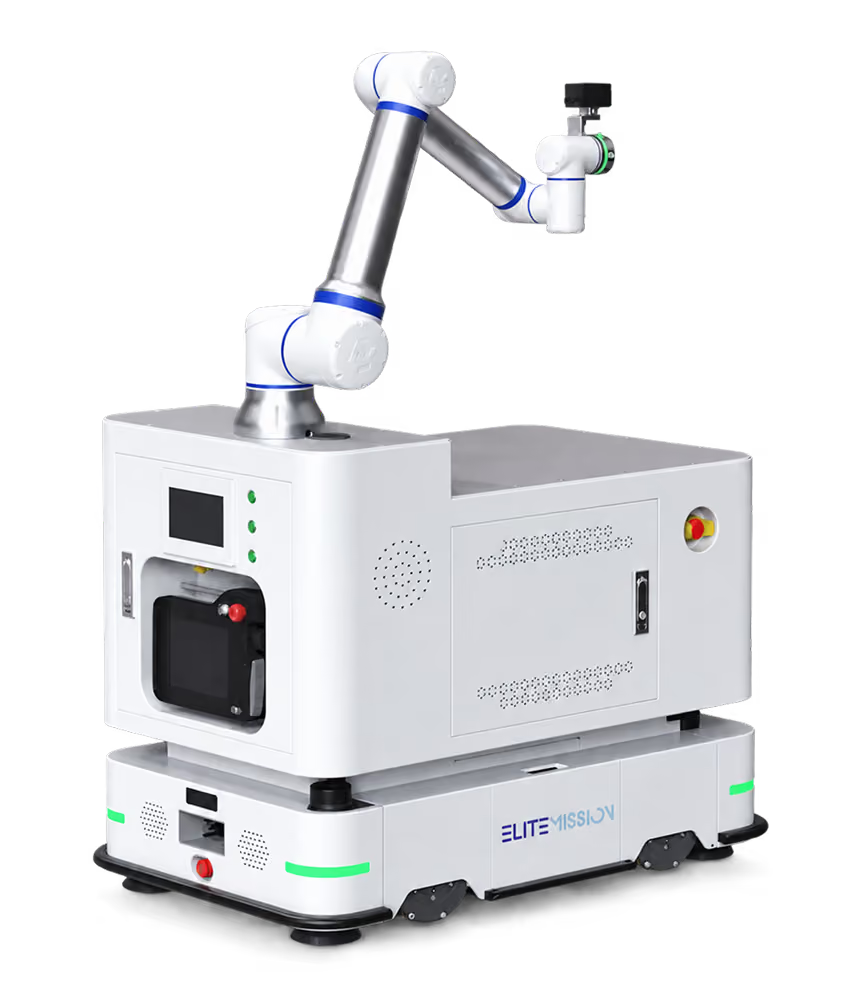





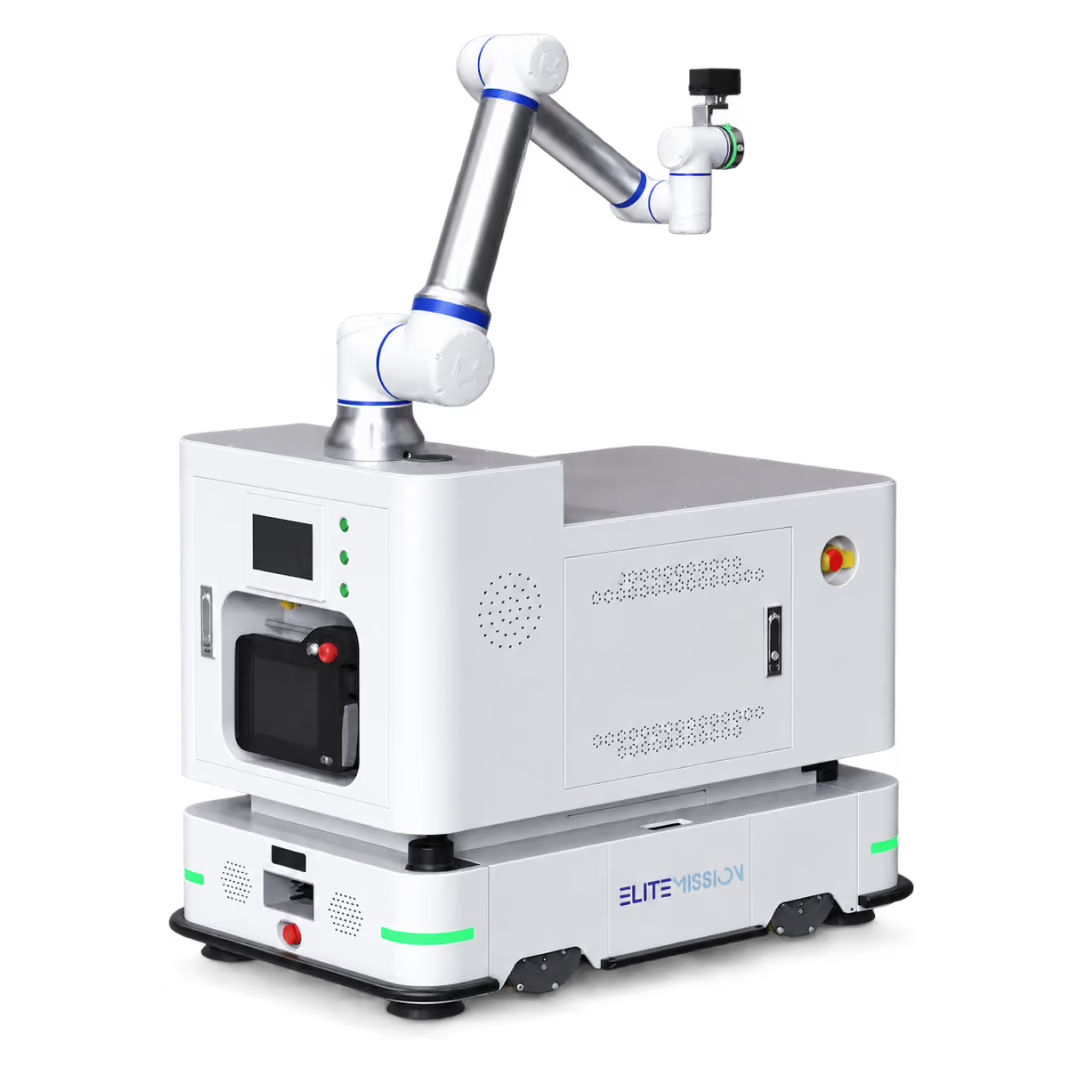
MC500-12


Name Parameter
Net Weight/Payload400 KG | 300 KG
Dimensions1080×660×850 mm
Working Radius1304 mm
Arm Payload12 KG
Maximum Speed1.5 m/s
Integrated Positioning Accuracy (2.5D)±0.2 mm
Navigation Positioning AccuracyReflectorless: ±10 mm; Reflective: ±5 mm
Battery Capacity48V/60Ah
Charging MethodRapid Battery Swap, Manual/Automatic Charging
Spec Parameter
Payload 25kg
Radius 1500mm
Repeatability ±0.8mm
Axis 6
Max Pallet Size 1200 mm * 1000 mm
Max Stacking Height 2300mm
Weight428 kg
Spec Parameter
Payload 30kg
Radius 1522mm
Repeatability ±0.1mm
Axis 5
Max Pallet Size 1200 mm * 1000 mm
Max Stacking Height 2300mm
Weight 400 kg
Spec Parameter
Model CH-A143/85
Weight 20 kg
Dimensions 410 × 320 × 270 mm
Charging
Connector Height 143/85 ±10 mm
Input Voltage AC 220 V ±10% (16 A GB-standard plug)
Input Current <10 A
Frequency 50 Hz
Rated Voltage DC 48 V
Maximum
Voltage DC 58.4 V
Output Current Max 50 A
Number of
Output Channels 1 Channel
Ethernet Port Supported
Supported
Protocols Modbus TCP
Spec Parameter
Payload 25kg
Radius 1500mm
Repeatability ±0.8mm
Axis 6
Max Pallet Size 1200 mm * 1000 mm
Max Stacking Height 1600mm
Weight 380 kg
Spec Parameter
Payload 30kg
Radius 1522mm
Repeatability ±0.1mm
Axis 5
Max Pallet Size 1200 mm * 1000 mm
Max Stacking Height 1600mm
Weight 380 kg
Spec Parameter
Model CH-MS60/40
Weight 68 kg
Dimensions 842 × 600 × 441 mm
Compatible
Battery 60 Ah / 40 Ah
Input Voltage AC 220 V ±10% (Dual-channel 10 A GB-standard plug)
Input Current <10 A
Frequency 50 Hz
Rated Voltage DC 48 V
Maximum
Voltage DC 58.4 V
Output Current 25/30 A
Number of
Output Channels 2 Channel
Ethernet Port Supported
Supported
Protocols Modbus TCP
Spec Parameter
Temperature range 0~50℃
Peak Power Consumption 2~3.5kW
Power Source Single-phase 220VAC/110VAC 50~60Hz
Footprint 1400mm x 1700mm
Spec Parameter
Size 301mm x 232mm x 54mm
Screen size 12.1"
Resolution 1280 x 800 pixels
IP rating IP54
Weight1.7 kg
Cable length5.5 m
Temperature range0~50℃
Relative humidity5%–95% (non-condensing)
MaterialAluminum, Plastic, Rubber
Input methodCapacitive touch-screen
Spec Parameter
Size 301 mm x 232 mm x 105 mm
Screen size 12.1"
Resolution 1280 x 800 pixels
IP rating IP54
Weight 1.8 kg
Cable length 5.5 m
Temperature range0~50℃
Relative humidity5%–95% (non-condensing)
Material Aluminum, Plastic, Rubber
Input methodCapacitive full touch-screen, 3-mode enable key, jogging-keys, function keys
MC500-12
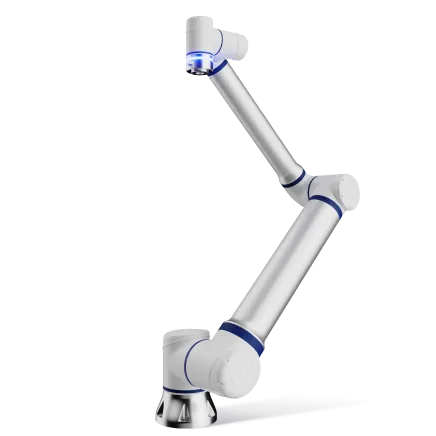
MC500-12 is an omnidirectional mobile manipulator combining a 300 kg-payload mobile platform with a 12 kg-payload collaborative robotic arm for flexible and precise mobile manipulation.


Collaborative Robotic Arm
Pair MN500 with CH-A143/85 or CH-MS60/40 smart charging stations for automatic charging and efficient fleet operation.


2.5D Vision System
Self-developed 2.5D vision, combined with IMU positioning, enables ±0.2 mm integrated positioning accuracy for precise mobile manipulation.


M-ATCS Autonomous Transportation Control System
Enables unified AGV/AMR scheduling, smart-device integration, cloud deployment, and rapid integration with existing IT systems.
Unified Controller
Integrates the mobile platform, robotic arm, sensors, safety management, and task scheduling within a unified control architecture.


Components highlights